Loading...
Searching...
No Matches
Public Types |
Public Member Functions |
Protected Member Functions |
Protected Attributes |
List of all members
FST::Search_Branch_And_Bound_Partial_Prediction< RETURNTYPE, DIMTYPE, SUBSET, CRITERION, PREDICTOR > Class Template Reference
Implements Branch and Bound with Partial Prediction (BBPP) method, i.e., with predicted node ordering. More...
#include <search_branch_and_bound_partial_prediction.hpp>
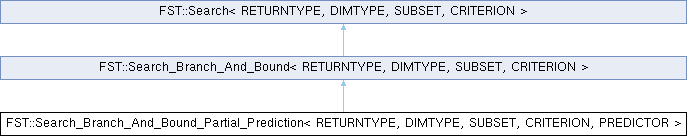
Inheritance diagram for FST::Search_Branch_And_Bound_Partial_Prediction< RETURNTYPE, DIMTYPE, SUBSET, CRITERION, PREDICTOR >:
Public Types | |
| typedef Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | parent |
| base class alias | |
| typedef parent::PCriterion | PCriterion |
| shared pointer to the criterion the search optimizes | |
| typedef parent::PSubset | PSubset |
| shared pointer to a feature subset | |
| typedef parent::PNode | PNode |
| pointer to a search-tree Node, see Search_Branch_And_Bound | |
| typedef parent::Node | Node |
| search-tree node record (feature, value, type, valid), see Search_Branch_And_Bound | |
| typedef parent::NodeType | NodeType |
| UNKNOWN/RANDOM/PREDICTED/COMPUTED node-value provenance, see Search_Branch_And_Bound. | |
| typedef parent::PEvaluatorEngine | PEvaluatorEngine |
| shared pointer to the injected evaluation-strategy engine | |
| Public Types inherited from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| typedef Search< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | parent |
| base class: the abstract Search interface (search(), progress reporting, result tracker) | |
| typedef std::shared_ptr< CRITERION > | PCriterion |
| shared pointer to the criterion under optimization | |
| typedef std::shared_ptr< SUBSET > | PSubset |
| shared pointer to a feature subset | |
| typedef Candidate_Evaluator< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | EVALUATORENGINE |
| the injected candidate-evaluation strategy type (sequential-inline or thread-pooled); process_leafs(), and descendants' pre_evaluate_availables()/post_process_tree_level() overrides, batch candidate evaluations through it | |
| typedef std::shared_ptr< EVALUATORENGINE > | PEvaluatorEngine |
| shared pointer to an EVALUATORENGINE, as accepted by the constructor and returned by get_engine() | |
| Public Types inherited from FST::Search< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| typedef std::shared_ptr< CRITERION > | PCriterion |
| shared pointer to the criterion the search optimizes | |
| typedef std::shared_ptr< SUBSET > | PSubset |
| shared pointer to a feature subset | |
| typedef std::shared_ptr< Result_Tracker< RETURNTYPE, SUBSET > > | PResultTracker |
| shared pointer to the result tracker enabled via enable_result_tracking() | |
| typedef Search_Observer< RETURNTYPE, SUBSET > | OBSERVER |
| the observer interface type this search reports through (see Search_Observer) | |
| typedef std::shared_ptr< OBSERVER > | PObserver |
| shared pointer to an OBSERVER, as set via set_observer() | |
Public Member Functions | |
| Search_Branch_And_Bound_Partial_Prediction (PEvaluatorEngine engine=PEvaluatorEngine()) | |
engine forwarded to Search_Branch_And_Bound; defaults to sequential in-line evaluation if not supplied | |
| virtual std::ostream & | print (std::ostream &os) const override |
| Writes the algorithm's name together with the prediction mechanism in use, and the thread count when a threaded evaluation engine is injected. | |
| Public Member Functions inherited from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| Search_Branch_And_Bound (PEvaluatorEngine engine=PEvaluatorEngine()) | |
| Constructs the search, optionally injecting a candidate-evaluation engine. | |
| virtual bool | search (const DIMTYPE target_d, RETURNTYPE &result, const PSubset sub, const PCriterion crit, std::ostream &os=std::cout) override |
| returns the found subset of exactly target_d features + its criterion value; target_d must be nonzero (Branch & Bound searches one fixed cardinality, it does not optimize it) | |
| Public Member Functions inherited from FST::Search< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| void | enable_result_tracking (PResultTracker tracker) |
| assigns a result tracker to the search process, i.e., enables logging of all evaluated subsets for future reuse (re-evaluation, etc.) | |
| void | disable_result_tracking () |
| detaches any result tracker (result_tracker_active() then returns false) | |
| bool | result_tracker_active () const |
| true if a result tracker was assigned via enable_result_tracking() and not since disabled | |
| void | set_output_detail (OutputDetail detail) |
| sets the amount of information that is logged to output stream throughout the course of search | |
| OutputDetail | get_output_detail () const |
| the currently configured output detail level | |
| bool | output_normal () const |
| true unless output detail is SILENT | |
| bool | output_detailed () const |
| true only at the DETAILED output level | |
| void | set_observer (PObserver observer) |
redirects search progress reporting away from the default syncout text output to observer | |
Protected Member Functions | |
| virtual void | initialize (const DIMTYPE d, const DIMTYPE n, const PCriterion crit) override |
resets the prediction mechanism for a feature space of n features; nothing else needs setting up for BBPP | |
| virtual void | leaf_result (const DIMTYPE feature, const RETURNTYPE value) override |
| virtual void | pre_evaluate_availables () override |
| Assigns an ordering value to every available feature: predicted (parent value minus the predicted contrast) where the predictor already has evidence for that feature, otherwise the exact criterion value, obtained in one batch through the evaluation engine and fed back to the predictor. | |
| virtual void | post_process_tree_level () override |
| Replaces the merely PREDICTED values of the nodes that made it into the new tree level by exact criterion values (again in one engine batch). This is what makes the method PARTIAL prediction: predictions decide the ORDER of the level only, while every node on the tree path carries a true value, so a cut is never based on an estimate and optimality is preserved. | |
| virtual bool | cut_possible () override |
| Returns true when the current node's value does not exceed the current bound, so the whole sub-branch below it can be cut. The value is always exact here (post_process_tree_level() has made it COMPUTED), so no lazy evaluation is needed; returns false while no bound is valid yet. | |
| Protected Member Functions inherited from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| PCriterion const & | get_criterion () const |
| accessor for _criterion, for use by descendant B&B variants' hooks | |
| PEvaluatorEngine const & | get_engine () const |
| accessor for the injected evaluation strategy (sequential-inline or thread-pooled), for use by descendant B&B variants' hooks | |
| RETURNTYPE | get_bound_value () const |
| the current best (bound) criterion value; meaningful only once is_bound_valid() | |
| bool | is_bound_valid () const |
| true once a valid bound has been established, see _boundvalid | |
| int | get_k () const |
| the tree depth/level currently being processed (root is 0; the deepest stored level is n-d-1, and level n-d is the leaf level, evaluated but never stored). The return type is int, while the member k is DIMTYPE | |
| DIMTYPE | get_n () const |
| total number of features, see n | |
| DIMTYPE | get_d () const |
| target subset cardinality, see d | |
| bool | getFirstNode (PNode &nod) |
| begins forward iteration (ascending by value, from _tree[k].begin()) over the current level's not-yet-decided nodes into nod; returns false if the level is empty | |
| bool | getNextNode (PNode &nod) |
| advances the getFirstNode() iteration; returns false once the level's end is reached | |
| bool | getFirstAvailable (PNode &avail) |
| begins iteration over _available in feature-index order, skipping withdrawn (invalid) entries, into avail; returns false if none are available | |
| bool | getNextAvailable (PNode &avail) |
| advances the getFirstAvailable() iteration, again skipping invalid entries; returns false once exhausted | |
| bool | getAvailable (DIMTYPE idx, PNode &avail) |
| direct lookup of _available[idx] by feature index, regardless of its valid flag; returns false if idx is out of range | |
| PSubset & | get_currentset () |
| mutable accessor for _currentset, for use by descendant B&B variants' hooks | |
| Node & | get_parent_node () |
| the node one level up (_tree[k-1].back()) whose feature removal defines the branch currently being followed; valid at the leaf level too (k==n-d==_tree.size(), the unstored leaf level whose parent is the last stored one), which is where FBB/BBPP's leaf hooks call it | |
| Node & | get_current_node () |
| the node at the current level k presently being visited (_tree[k].back()), i.e. about to be tested for cutting or descended into | |
| void | setup_default_structures (const DIMTYPE d, const DIMTYPE n) |
| Allocates and resets everything one search() run needs: the n-d stored tree levels (all emptied), the _available pool (all n features valid), _currentset (all features selected, i.e. the root), the _tempset scratch subset and the _boundset holder (bound marked invalid). | |
| void | update_bound (const RETURNTYPE val, const PSubset &sub) |
| Registers one fully-evaluated candidate subset of target cardinality d against the running bound. Updates _boundset/_boundvalue/_boundvalid whenever val improves on (or is the first) bound and, at NORMAL output or above, reports the improvement as a new solution; unconditionally feeds (val,sub) to the result tracker if one is active. Called from process_rightmost_path() and from process_leafs()'s per-leaf engine callback. | |
| void | make_tree_level () |
| Builds the k-th tree level (_tree[k]), keeping exactly n-d-k+1 candidates in reserve for the levels still to come. Calls pre_evaluate_availables() to obtain each still-available feature's ordering value, sorts the best (levelsize = get_available_size()-(n-d-k+1)) of them ascending by value into _tree[k] (withdrawing the chosen features from _available via available_remove()), then calls post_process_tree_level() so a descendant can substitute exact values for any node whose ordering value was only an estimate. | |
| void | process_rightmost_path () |
| Evaluates and registers the "rightmost" leaf reachable from the current branch by removing every feature still in _available at once. Copies _currentset into _tempset, deselects every remaining available feature, evaluates the criterion on the result and passes it to update_bound() - this seeds/tightens the bound as soon as each new tree level is built, before further descent, so later cuts can trigger sooner. | |
| virtual void | process_leafs () |
| engine-routed leaf evaluation; descendants hook per-leaf work via leaf_result() instead of overriding this | |
| Protected Member Functions inherited from FST::Search< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| void | report (std::ostream &os, const msgbuf &m) const |
| delivers one pre-formatted progress message: to the observer if attached, otherwise as syncout text to os | |
| void | report_solution (std::ostream &os, const RETURNTYPE value, const SUBSET &sub, const msgbuf &m) const |
| like report(), for sites announcing a new (sub-)solution; fires on_solution instead | |
Protected Attributes | |
| PREDICTOR | _predictor |
| the prediction mechanism instance (PREDICTOR type parameter, e.g. Branch_And_Bound_Predictor_Averaging); used only to ORDER each tree level's nodes (unlike FBB, BBPP always computes the true value along the tree path before deciding to cut, so optimality never relies on the prediction being accurate) | |
| Protected Attributes inherited from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| std::ostream * | shared_os |
| to enable sharing the same stream across the methods below | |
| std::shared_ptr< StopWatch > | swatch |
| stopwatch for the running search, (re)created at the start of search() and reported alongside progress/solution messages | |
| Protected Attributes inherited from FST::Search< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| PResultTracker | _tracker |
| the assigned result tracker, or null (see enable_result_tracking()/result_tracker_active()) | |
| OutputDetail | _detail |
| the output detail level set via set_output_detail(); read by output_normal()/output_detailed() | |
| PObserver | _observer |
| the attached progress observer, or null (see set_observer(), report(), report_solution()) | |
Additional Inherited Members | |
| Protected Types inherited from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION > | |
| enum | NodeType { UNKNOWN , RANDOM , PREDICTED , COMPUTED } |
| Marks how a Node's value was obtained: UNKNOWN = not yet assigned; RANDOM = reserved but currently unused by any B&B variant in this file; PREDICTED = filled from a PREDICTOR estimate pending confirmation (FBB/BBPP node ordering); COMPUTED = an exact criterion value. | |
| typedef Node * | PNode |
| pointer to a Node, as used by the getFirst.../getNext... accessors below | |
| typedef std::list< Node > | ListNode |
| one tree level's not-yet-decided candidate nodes, kept sorted ascending by value; the main search loop visits/pops from the back (highest value = most promising) via get_current_node() | |
| typedef std::vector< ListNode > | VectorListNode |
| the search tree: one ListNode per level, indexed by tree depth k (see _tree) | |
| typedef ListNode::iterator | ListNodeIter |
| iterator into a single tree level's ListNode, as used by _nodeiter/getFirstNode()/getNextNode() | |
| typedef std::vector< ListNode >::iterator | TreeLevelIter |
| iterator over tree levels (used only to clear _tree in setup_default_structures()) | |
| typedef std::vector< Node > | VectorNode |
| type of _available: one Node per original feature, indexed by feature id | |
Detailed Description
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
class FST::Search_Branch_And_Bound_Partial_Prediction< RETURNTYPE, DIMTYPE, SUBSET, CRITERION, PREDICTOR >
class FST::Search_Branch_And_Bound_Partial_Prediction< RETURNTYPE, DIMTYPE, SUBSET, CRITERION, PREDICTOR >
Implements Branch and Bound with Partial Prediction (BBPP) method, i.e., with predicted node ordering.
BBPP is generally slower than FBB but faster than IBB. Its principle is identical to that of Improved Branch & Bound (IBB), but it replaces large amount of criterion evaluations needed for ordering nodes in tree levels by quickly predicted values. The optimality of final result is not jeopardized but considerable amount of time is saved. See FBB for a more radical but still optimality preserving use of value prediction.
- Warning
- All Branch & Bound feature selection algorithms require the used CRITERION to be monotonic with respect to cardinality. More precisely, it must hold that removing a feature from a set MUST NOT increase criterion value. Otherwise there is no guarantee as of the optimality of obtained results with respect to the used criterion.
- Note
- All Branch & Bound algorithms by definition yield the solution with the same maximum criterion value, therefore the main concern regarding particular Branch & Bound algorithm is only its search speed.
- Due to possibly high number of subsets to be tested expect excessive computational time.
- Result tracking in case of Branch & Bound algorithms records only results of target cardinality.
Member Function Documentation
◆ cut_possible()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
overrideprotectedvirtual |
Returns true when the current node's value does not exceed the current bound, so the whole sub-branch below it can be cut. The value is always exact here (post_process_tree_level() has made it COMPUTED), so no lazy evaluation is needed; returns false while no bound is valid yet.
Implements FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
◆ initialize()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
inlineoverrideprotectedvirtual |
resets the prediction mechanism for a feature space of n features; nothing else needs setting up for BBPP
Implements FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
◆ leaf_result()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
overrideprotectedvirtual |
feeds one leaf's contrast (parent value minus leaf value) to the predictor, so the leaf level - the cheapest and most numerous evidence in the tree - also trains the ordering predictions
Reimplemented from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
◆ post_process_tree_level()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
overrideprotectedvirtual |
Replaces the merely PREDICTED values of the nodes that made it into the new tree level by exact criterion values (again in one engine batch). This is what makes the method PARTIAL prediction: predictions decide the ORDER of the level only, while every node on the tree path carries a true value, so a cut is never based on an estimate and optimality is preserved.
Implements FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
◆ pre_evaluate_availables()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
overrideprotectedvirtual |
Assigns an ordering value to every available feature: predicted (parent value minus the predicted contrast) where the predictor already has evidence for that feature, otherwise the exact criterion value, obtained in one batch through the evaluation engine and fed back to the predictor.
Implements FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
◆ print()
template<class RETURNTYPE, typename DIMTYPE, class SUBSET, class CRITERION, class PREDICTOR>
|
inlineoverridevirtual |
Writes the algorithm's name together with the prediction mechanism in use, and the thread count when a threaded evaluation engine is injected.
Reimplemented from FST::Search_Branch_And_Bound< RETURNTYPE, DIMTYPE, SUBSET, CRITERION >.
The documentation for this class was generated from the following file:
- /Users/psms/dev/devtest1/_src_search/search_branch_and_bound_partial_prediction.hpp
Generated by
 1.17.0