Loading...
Searching...
No Matches
FST::Branch_And_Bound_Predictor< RETURNTYPE, DIMTYPE > Class Template Referenceabstract
Defines Interface for Implementations of Prediction Mechanism in Fast Branch and Bound & Branch and Bound with Partial Prediction. More...
#include <branch_and_bound_predictor.hpp>
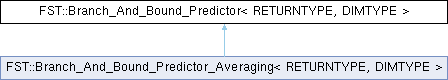
Inheritance diagram for FST::Branch_And_Bound_Predictor< RETURNTYPE, DIMTYPE >:
Public Member Functions | |
| virtual void | initialize (const DIMTYPE features)=0 |
(Re)initializes the predictor's per-feature state for features features; must be called before learn()/predict(), and again for every new search. | |
| virtual bool | learn (const DIMTYPE feature, const RETURNTYPE value)=0 |
Records an observed criterion value for feature, updating that feature's state only (see the class's per-feature isolation contract above). | |
| virtual bool | predict (const DIMTYPE feature, RETURNTYPE &value) const =0 |
Predicts feature's criterion value from its previously learn()ed observations, without evaluating the criterion. | |
| virtual std::ostream & | print (std::ostream &os) const |
| writes a human-readable identification of the predictor's learned state; base default writes nothing | |
Friends | |
| std::ostream & | operator<< (std::ostream &os, const Branch_And_Bound_Predictor< RETURNTYPE, DIMTYPE > &babp) |
Streams a predictor's print() (implementation-defined diagnostic state) to os. | |
Detailed Description
template<class RETURNTYPE, typename DIMTYPE>
class FST::Branch_And_Bound_Predictor< RETURNTYPE, DIMTYPE >
class FST::Branch_And_Bound_Predictor< RETURNTYPE, DIMTYPE >
Defines Interface for Implementations of Prediction Mechanism in Fast Branch and Bound & Branch and Bound with Partial Prediction.
- Warning
- CONTRACT relied on by the threaded FBB/BBPP bodies: predictor state must be isolated per feature - predict(f) may read only state learned for feature f, and learn(f) may modify only feature f's state. FBB/BBPP decide predict-vs-compute for a whole tree level upfront on the master thread and replay the learns in candidate order after the batched evaluations; that upfront pass gives the same decisions as deciding one candidate at a time exactly because no feature's decision can observe another feature's same-level learn. A predictor that let features share state would make the two passes differ, and threaded runs would stop reproducing sequential ones - do not implement one against this interface.
Member Function Documentation
◆ initialize()
template<class RETURNTYPE, typename DIMTYPE>
|
pure virtual |
(Re)initializes the predictor's per-feature state for features features; must be called before learn()/predict(), and again for every new search.
- Parameters
-
features number of features the predictor will track (features 0..features-1); must be at least 1
- Precondition
- features>=1 - a predictor tracking nothing has no use, and implementations assert against it
Implemented in FST::Branch_And_Bound_Predictor_Averaging< RETURNTYPE, DIMTYPE >.
◆ learn()
template<class RETURNTYPE, typename DIMTYPE>
|
pure virtual |
Records an observed criterion value for feature, updating that feature's state only (see the class's per-feature isolation contract above).
- Parameters
-
feature the feature this observation belongs to value the observed criterion value
- Returns
- false if the observation could not be recorded; implementations that never reject an observation return true unconditionally
Implemented in FST::Branch_And_Bound_Predictor_Averaging< RETURNTYPE, DIMTYPE >.
◆ predict()
template<class RETURNTYPE, typename DIMTYPE>
|
pure virtual |
Predicts feature's criterion value from its previously learn()ed observations, without evaluating the criterion.
- Parameters
-
feature the feature to predict a value for value set to the predicted value on success; left unspecified on failure
- Returns
- false if not enough observations are available yet for
feature– predict-vs-compute callers (FBB/BBPP) then fall back to actually evaluating the criterion for it
Implemented in FST::Branch_And_Bound_Predictor_Averaging< RETURNTYPE, DIMTYPE >.
◆ print()
template<class RETURNTYPE, typename DIMTYPE>
|
inlinevirtual |
writes a human-readable identification of the predictor's learned state; base default writes nothing
Reimplemented in FST::Branch_And_Bound_Predictor_Averaging< RETURNTYPE, DIMTYPE >.
The documentation for this class was generated from the following file:
- /Users/psms/dev/devtest1/_src_search/branch_and_bound_predictor.hpp
Generated by
 1.17.0